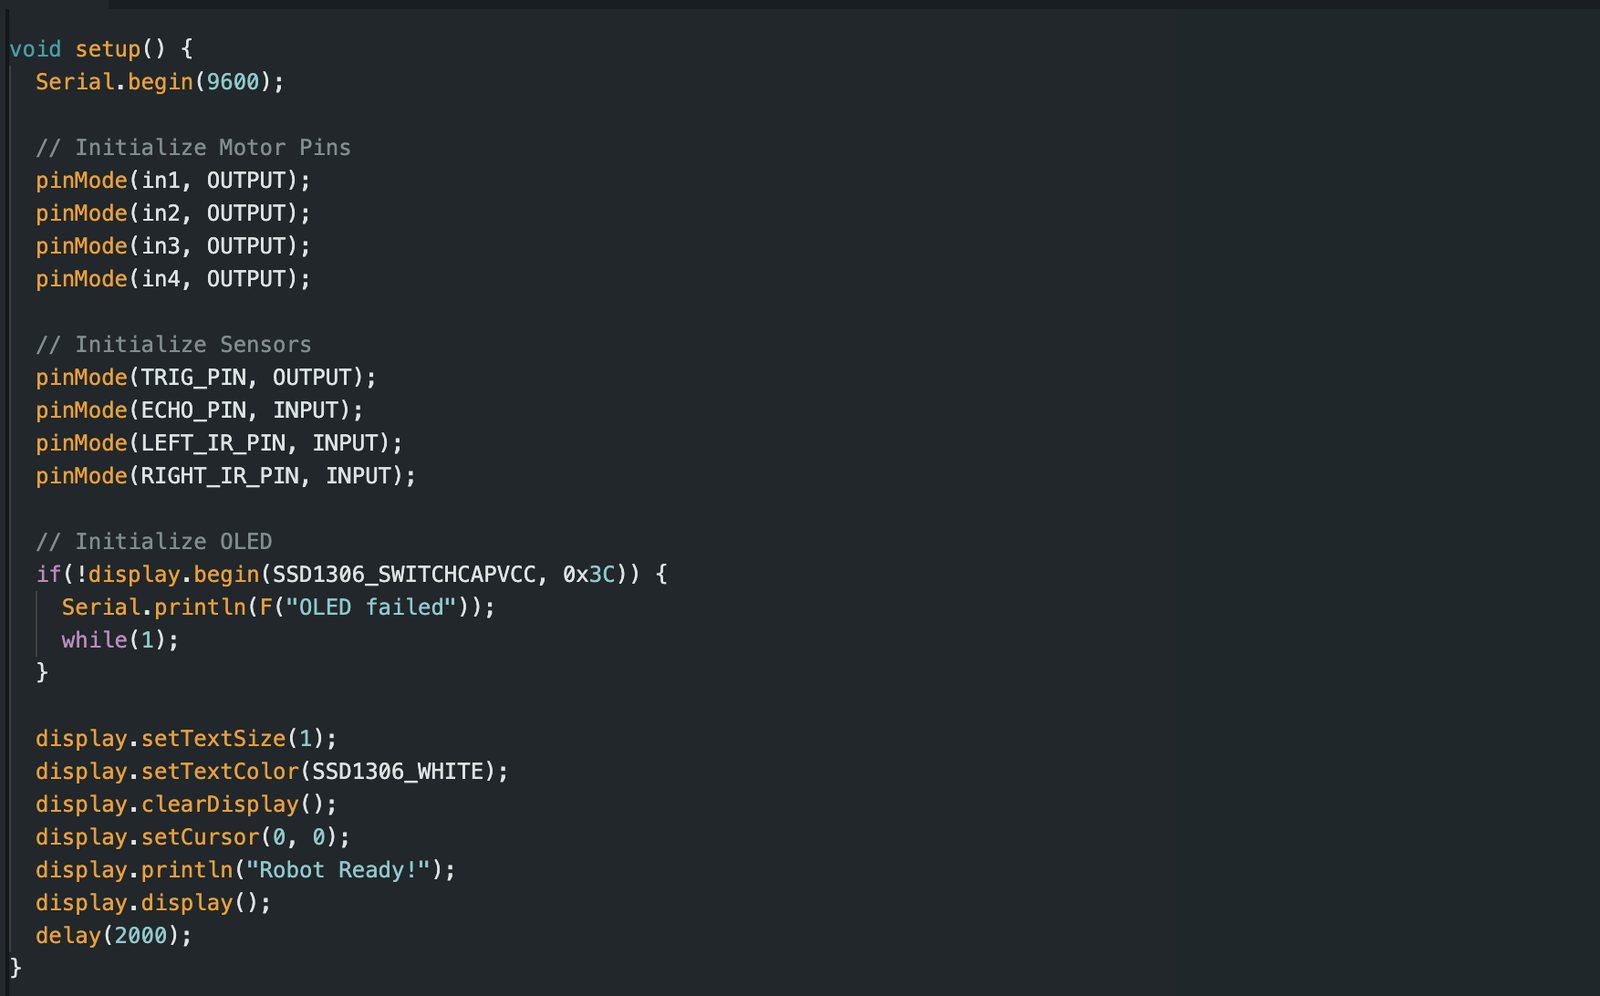
Obstacle-Avoiding RC Car (v3)
Personal project · 2024
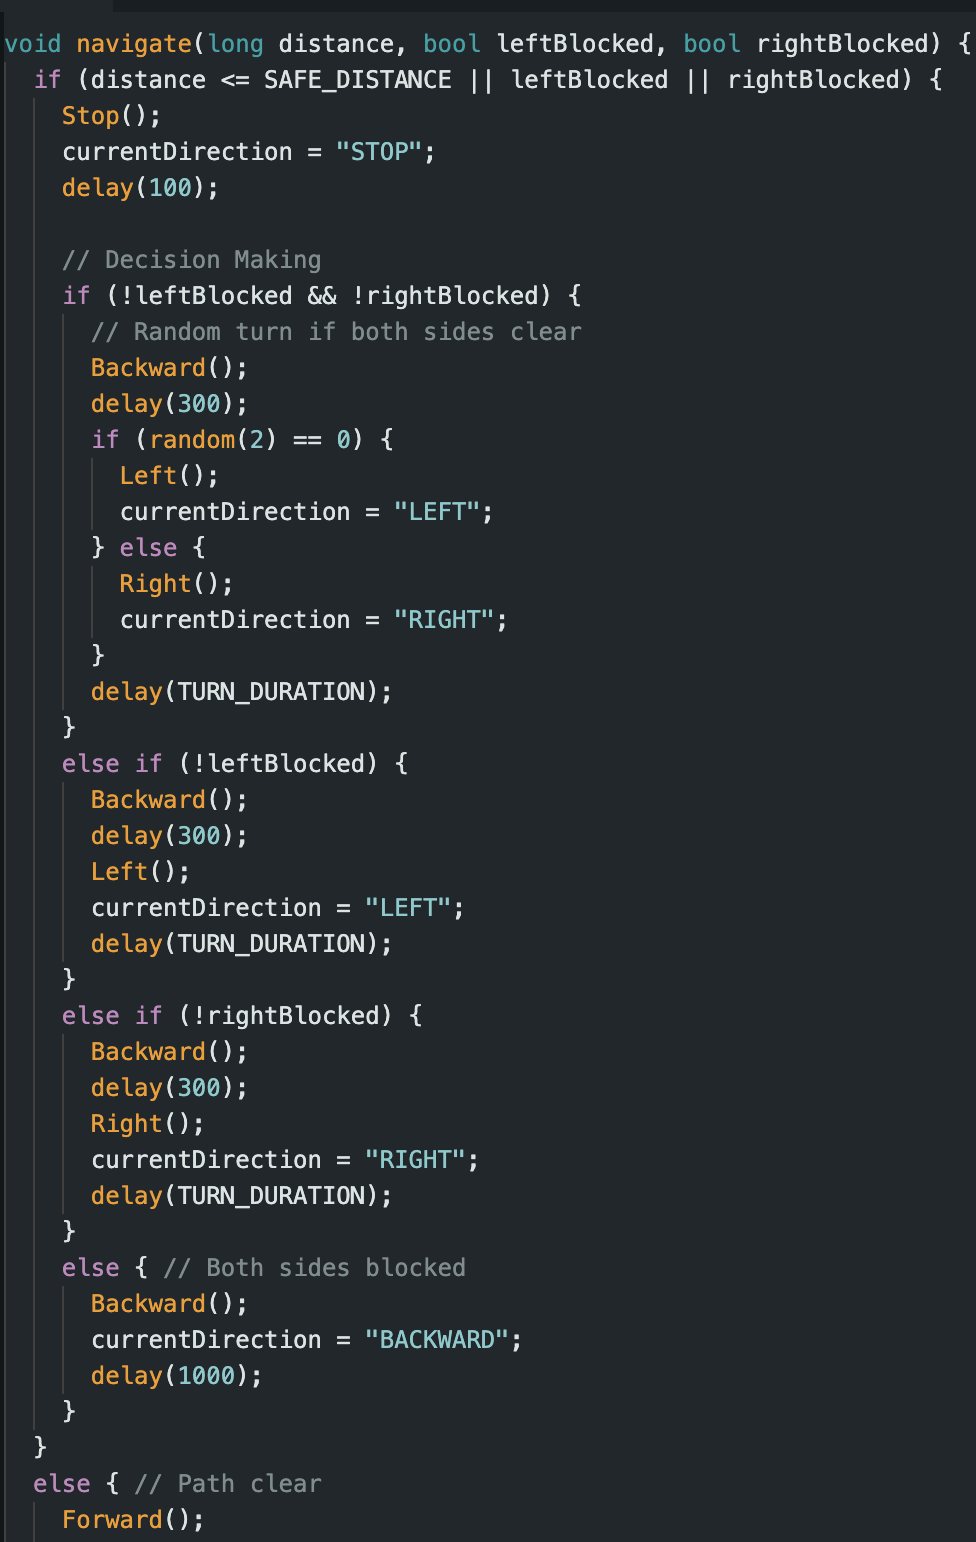
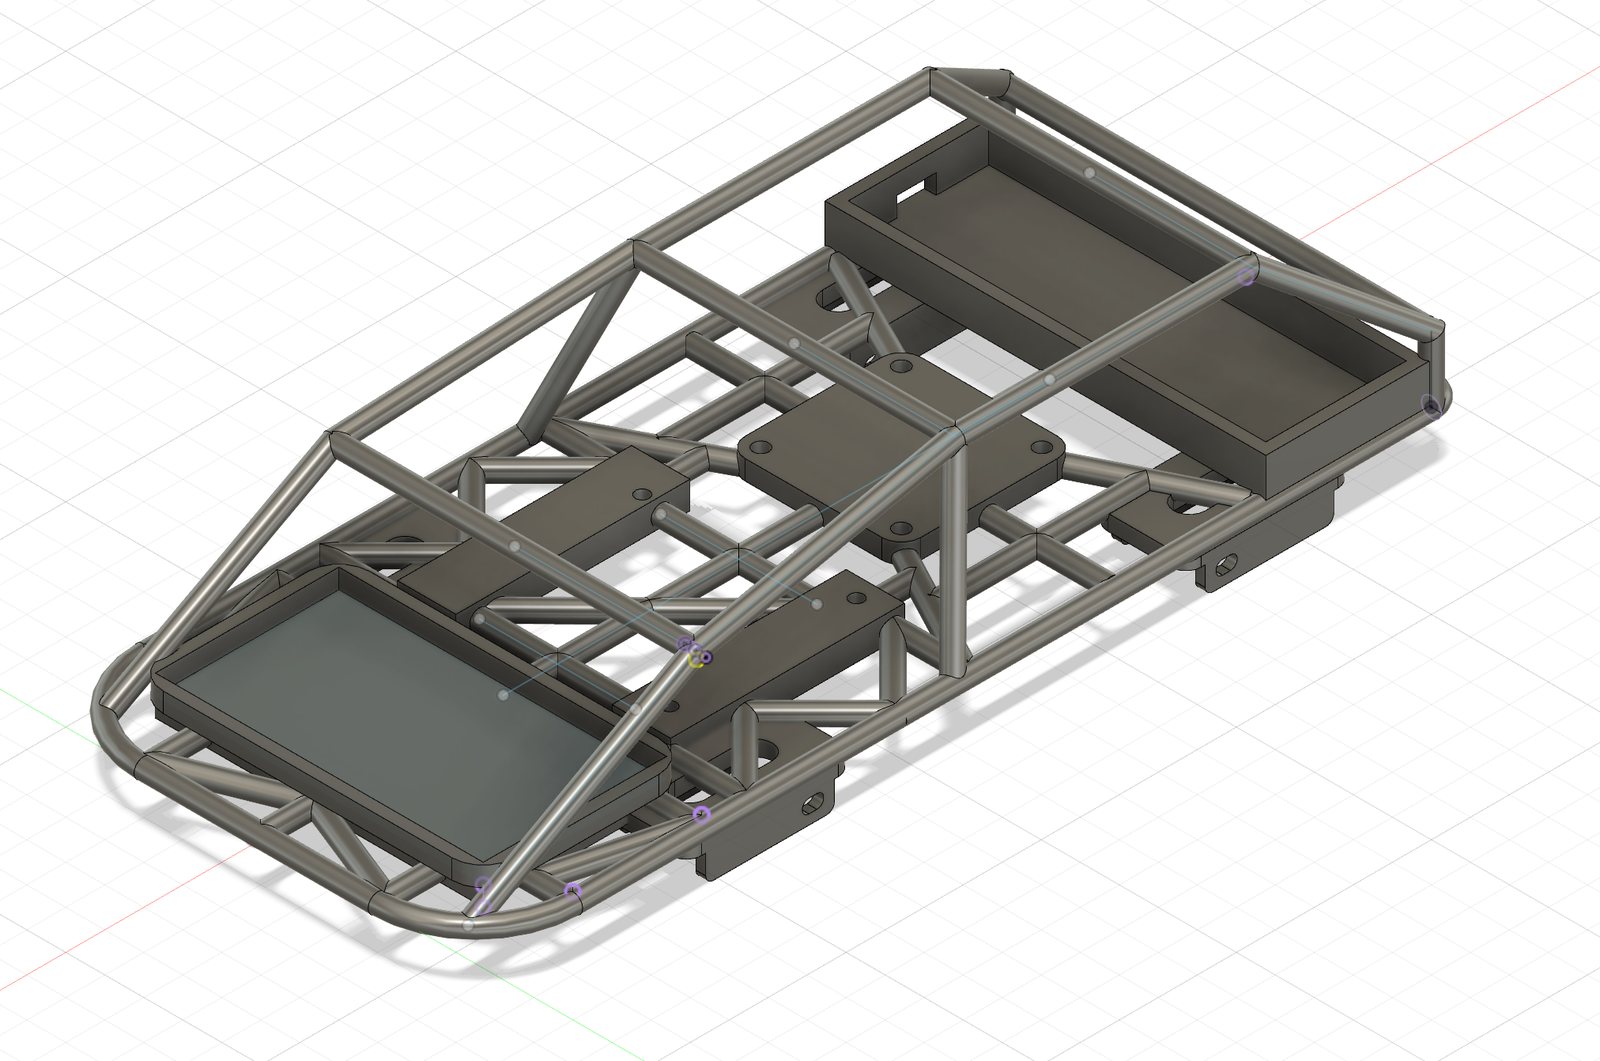
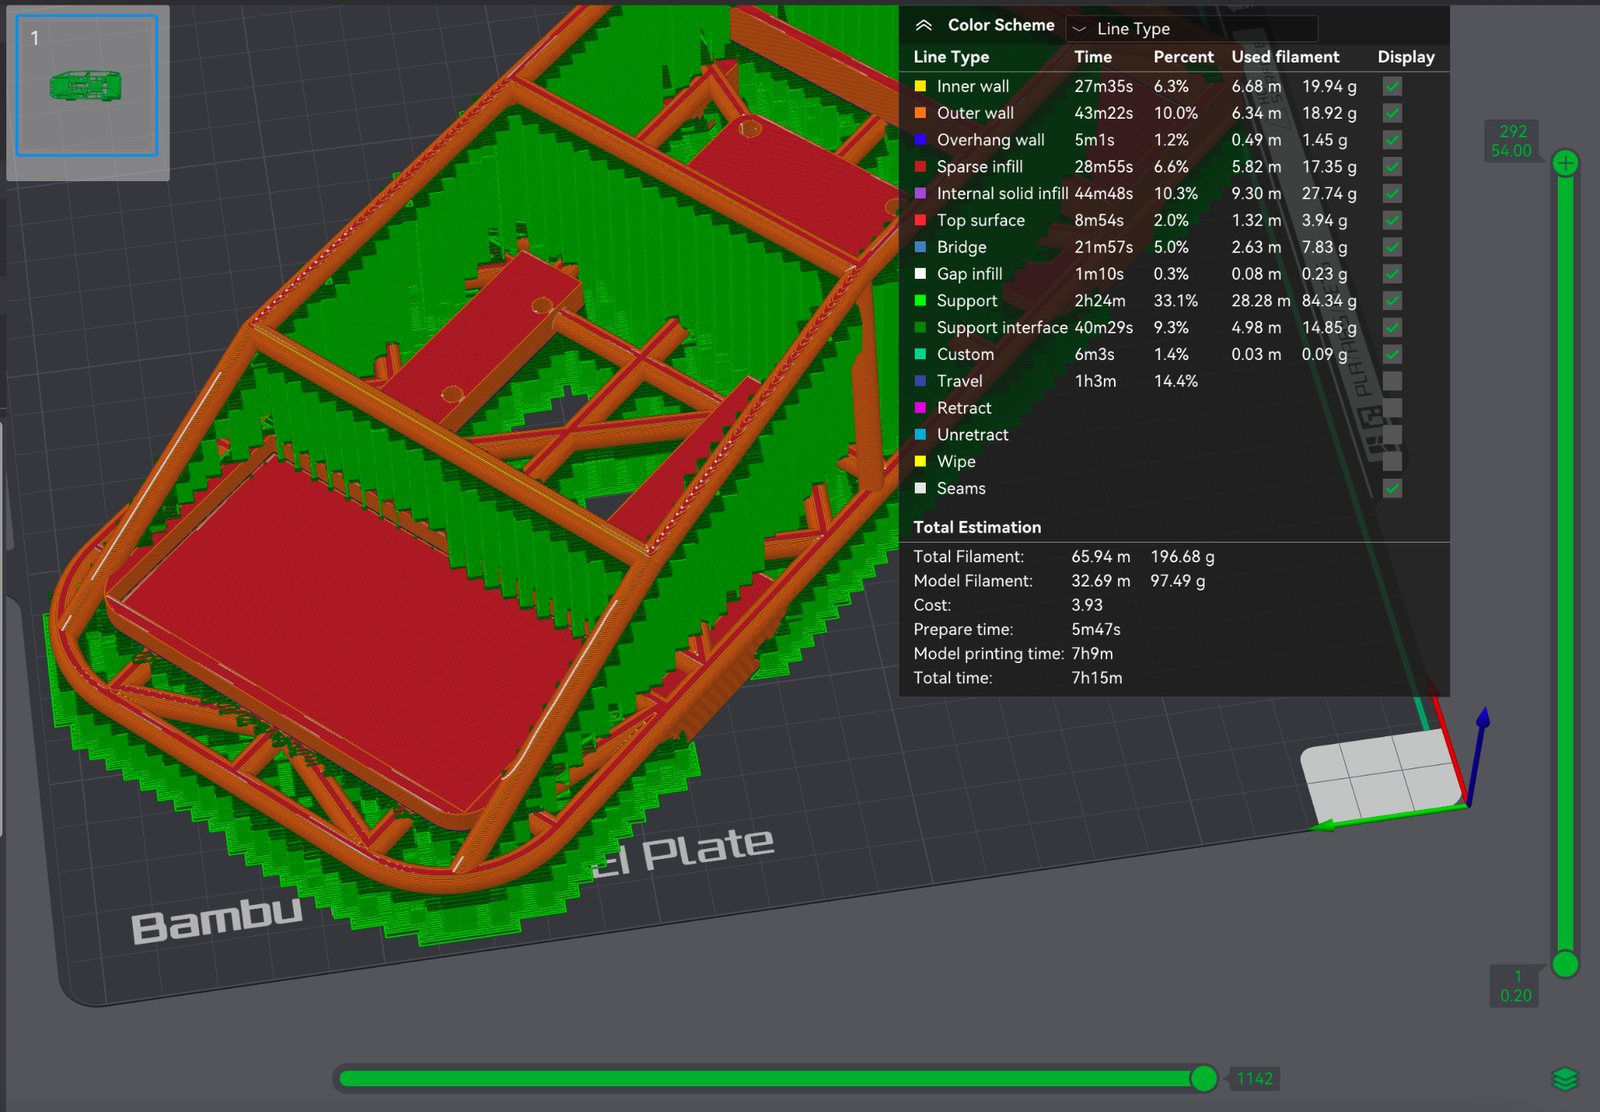
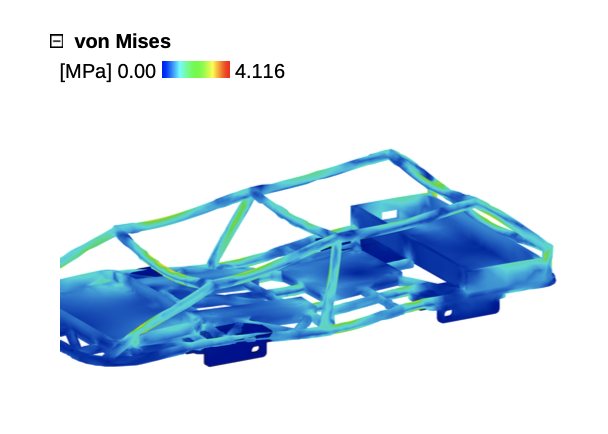
The third version of a 3D-printed RC car I designed from scratch: a stronger roll cage on a tube-style frame to cut material cost, a front ultrasonic sensor and side IR sensors so the car paths around obstacles autonomously, and an OLED showing live sensor readings and the direction decision. Chassis designed in Autodesk Fusion and printed on a Bambu printer.
Design & Print
Code
Sensors → check distance / IR → decision → motor action → repeat. Moves forward if the path is clear, stops and turns if an obstacle is near, and picks the clearest side. Detection range (15–30 cm) and turn speed are quick tweaks. Result: a strong roll cage and excellent obstacle avoidance, with fine tuning and rechargeable batteries next.